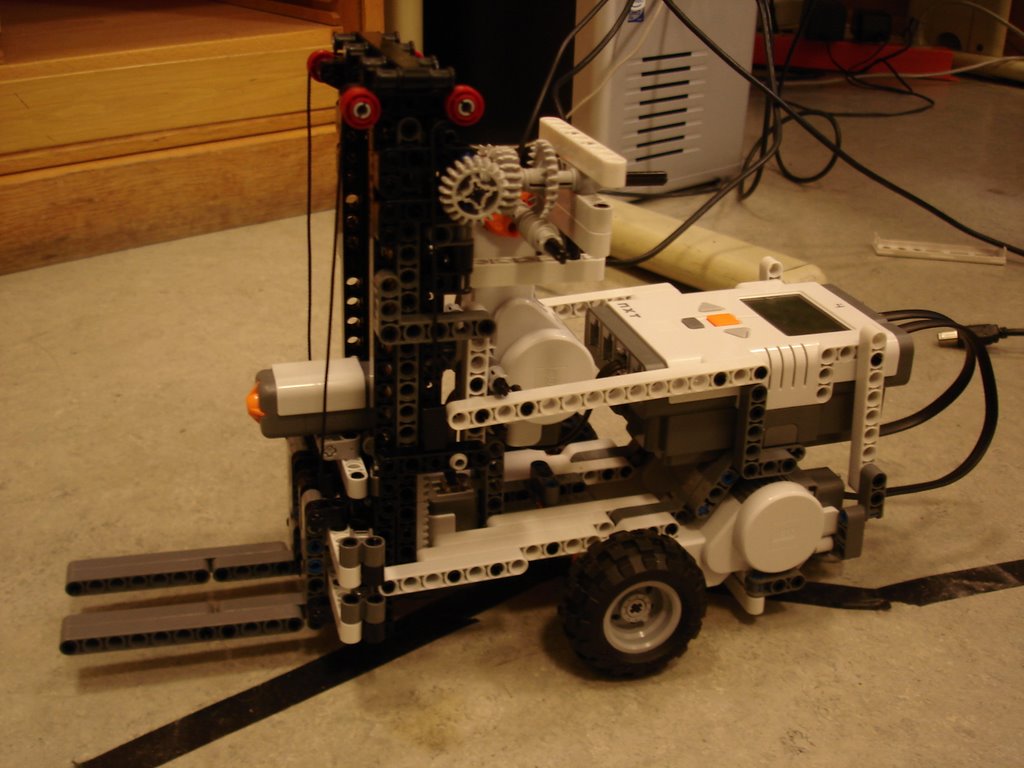
We archived to implement a simple algorithm that enables the NXT to follow a black line forming a circle. It is simple because the NXT can only go one way around and if the black line gets on the wrong side of the NXT, it it not able to find back on track.
After this was accomplished we tried to implement a sweep algorithm that would make the NXT go both ways.
We ran into some problems:
1. Not enough values from the light sensors
2. Can not count on tacho value.
We will continue to work on the FollowLine class, so hopefully it will be done next week.